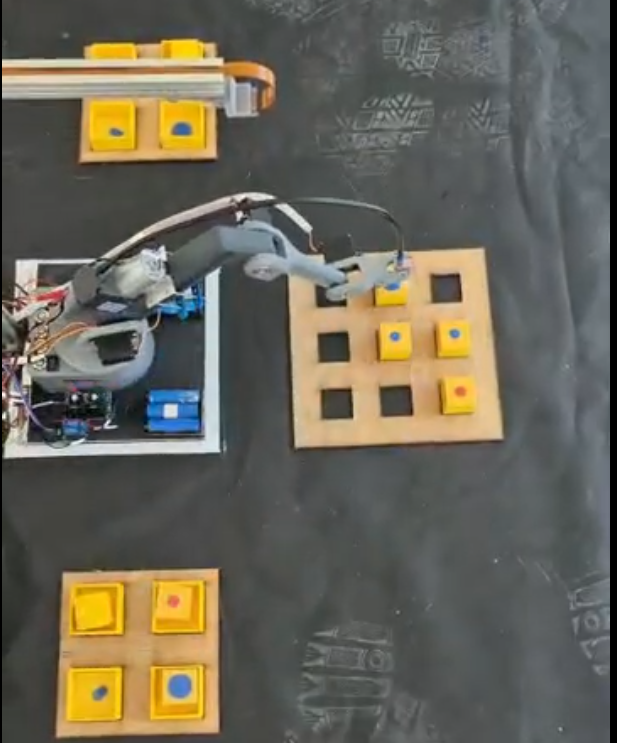
This project demonstrates an autonomous sorting workstation using a robotic arm equipped with computer vision. Utilizing a Raspberry Pi 5 and a high-resolution camera, the system identifies objects based on visual characteristics (color/shape).
Once detected, a robotic arm utilizes a pneumatic vacuum gripper to pick up the items and sort them into designated target zones. This simulates a real-world industrial automation line, bridging the gap between AI theory and practical mechanical
execution.
