
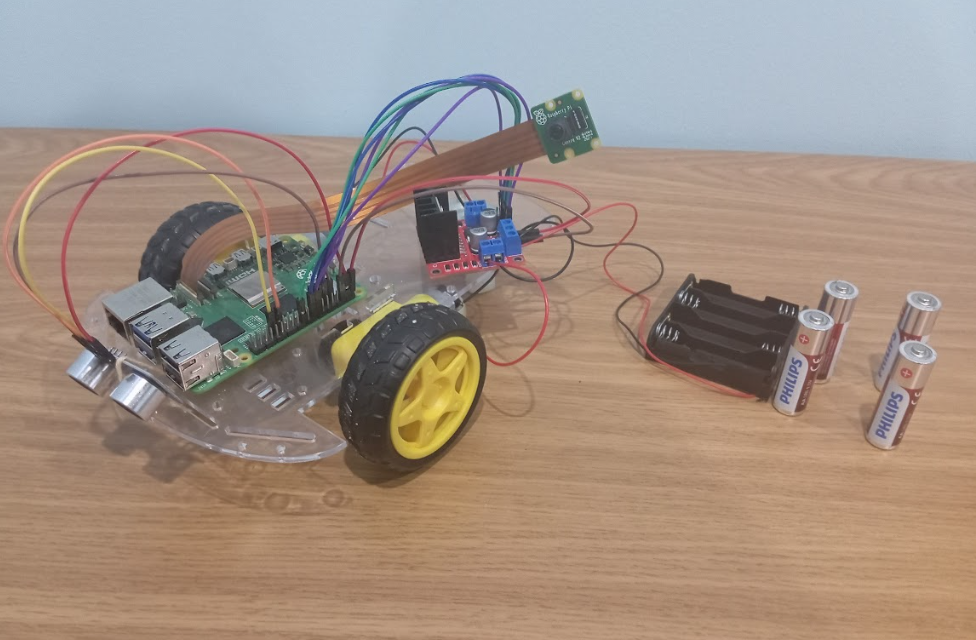
This project presents the development of a very basic autonomous smart vehicle capable of driving continuously using obstacle-avoidance logic based on ultrasonic distance sensing, while applying artificial intelligence object detection to identify waste materials in the environment - specifically cups and plastic bottles. The robot navigates independently by controlling two DC motors, avoiding collisions using a ultrasound sensor.
When the onboard camera detects waste (bottles), the vehicle pauses its movement and triggers a notification by sending a WhatsApp message through an HTTP request, simulating a smart trash-collection alert system. After sending the notification and waiting briefly, the vehicle resumes its autonomous driving routine. The purpose of the system is to demonstrate how AI and robotics can be combined to improve waste monitoring in public spaces, promote sustainability awareness, and encourage hands- on application of AI-driven automation.