
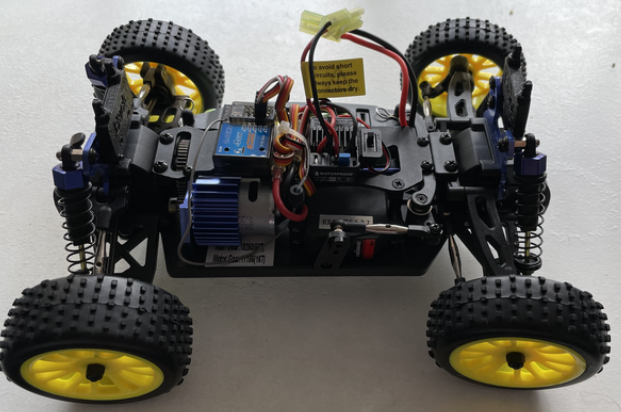
This project demonstrates how to build a small self‑driving robotic car using a Raspberry Pi, camera module, and computer vision techniques.
The system processes images captured from the camera to detect road lines and obstacles, allowing the vehicle to navigate autonomously.
Students learn how artificial intelligence, sensors, and robotics combine to create autonomous vehicle systems similar to those used in modern transportation research.